Research

Understanding the whole street scene.

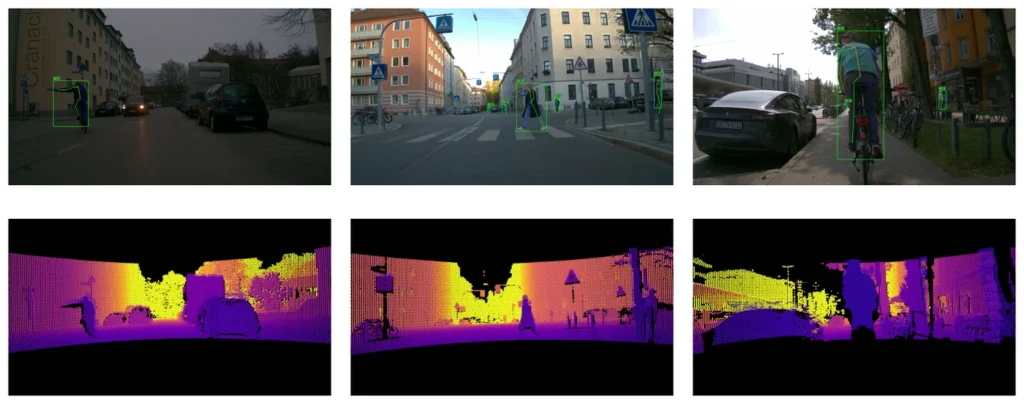
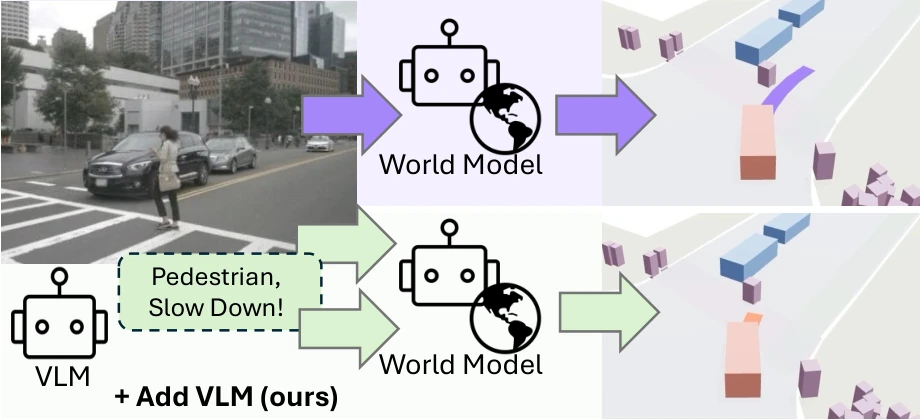
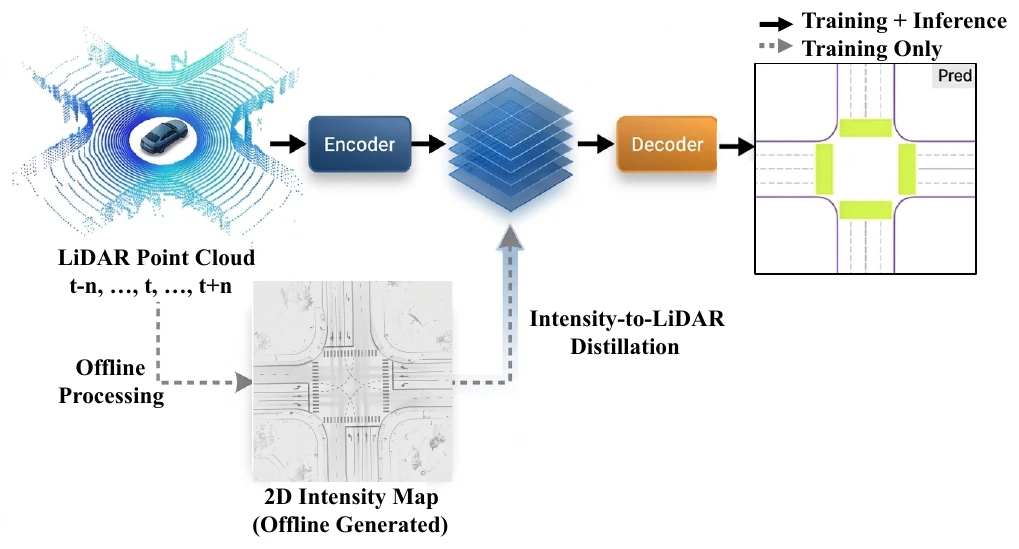
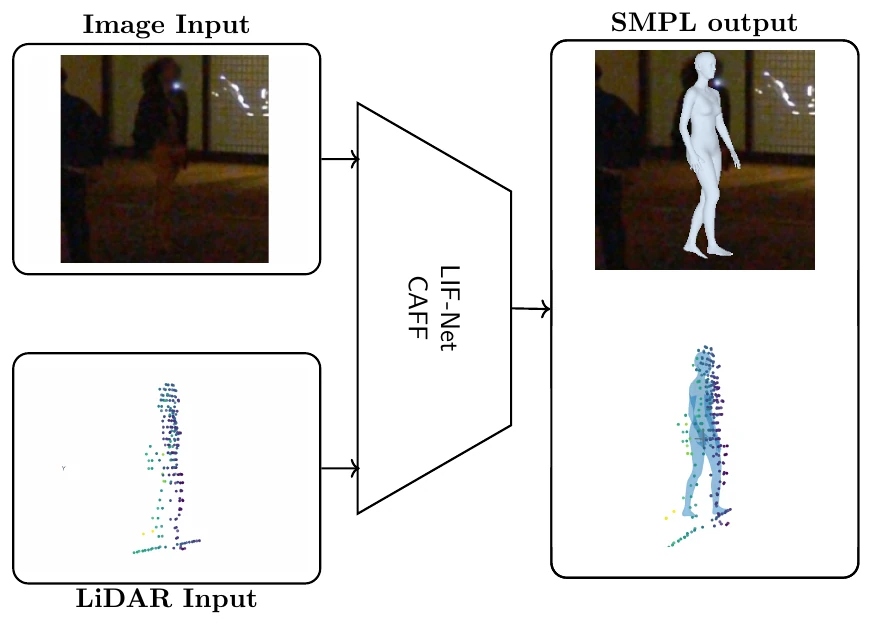
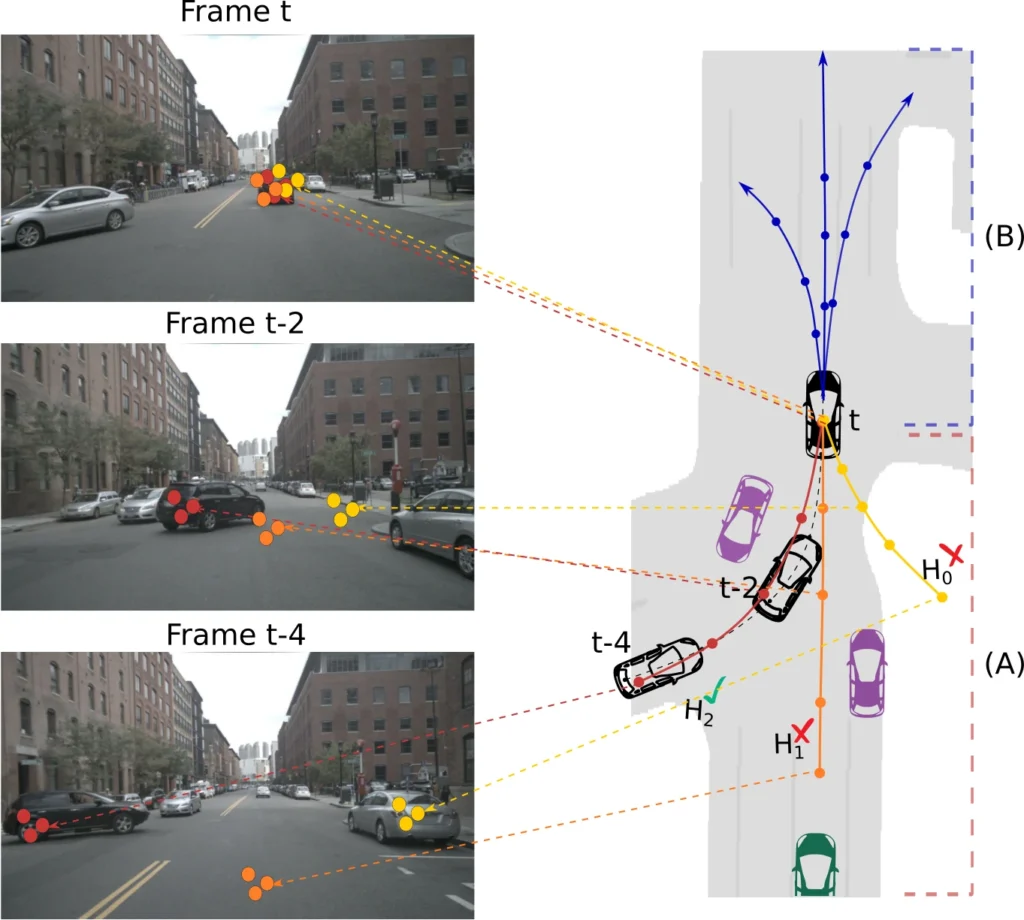
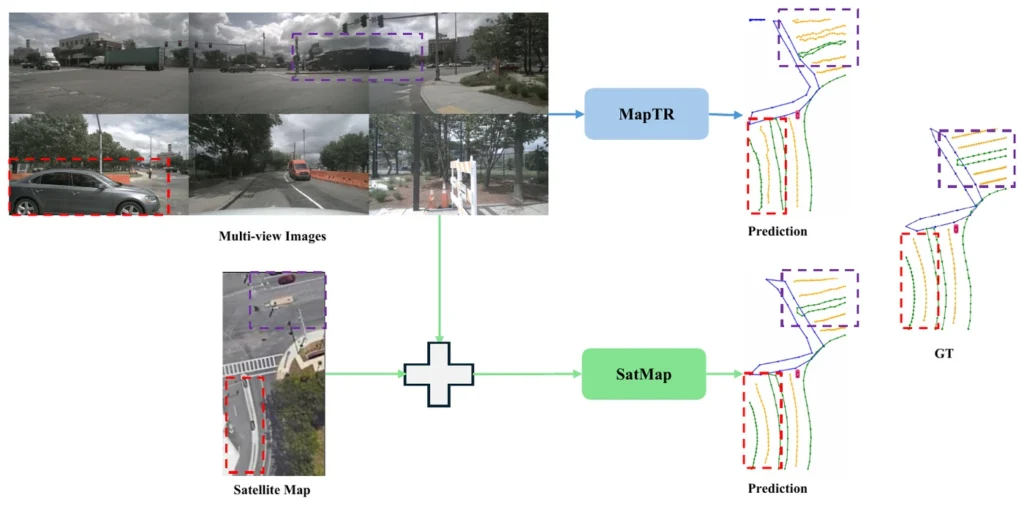
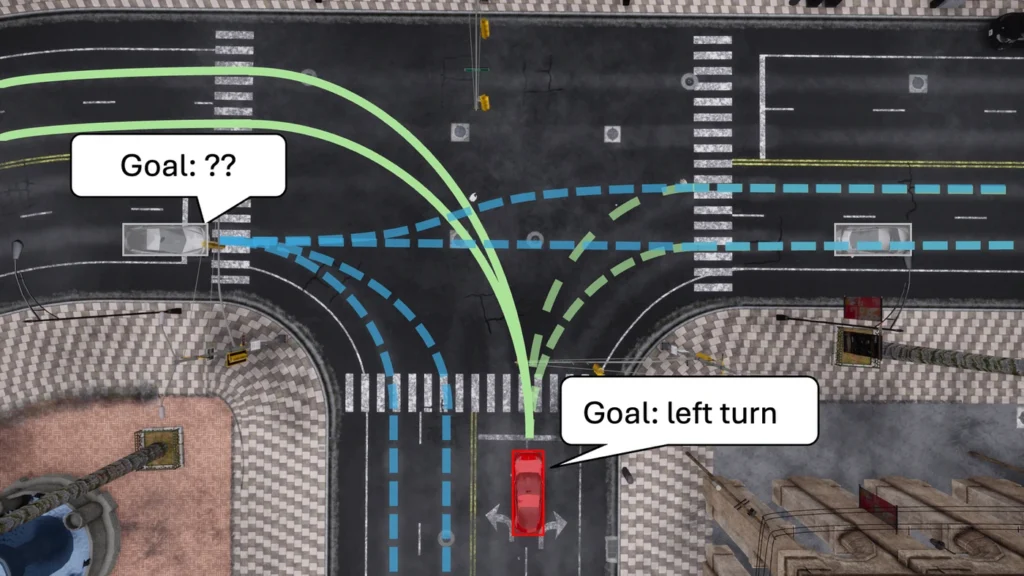
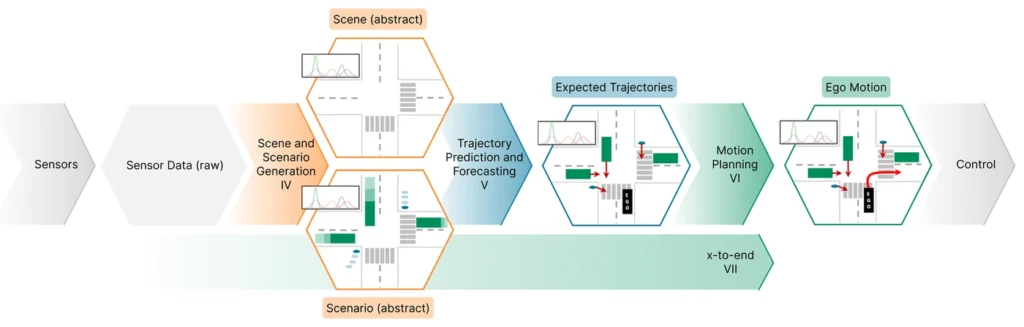
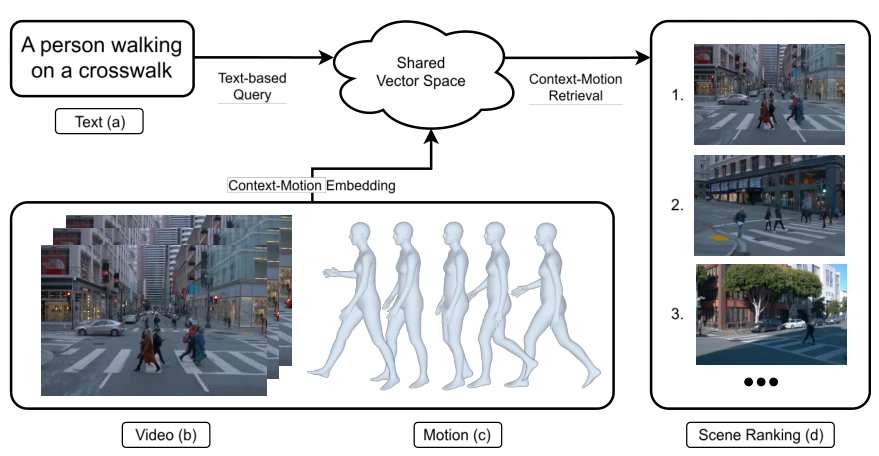
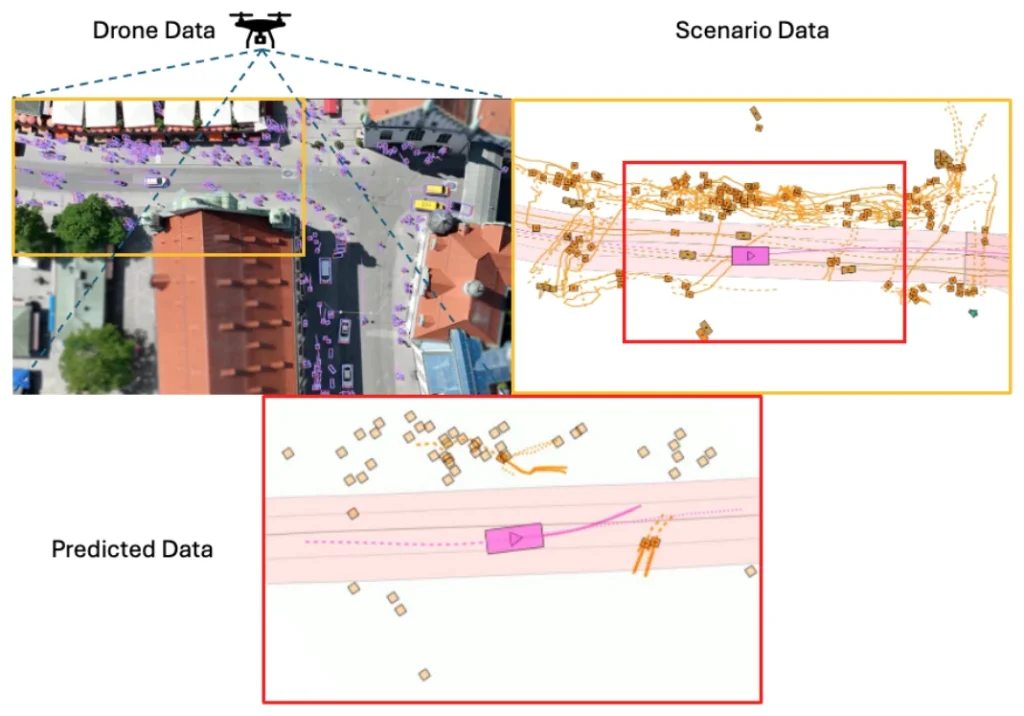
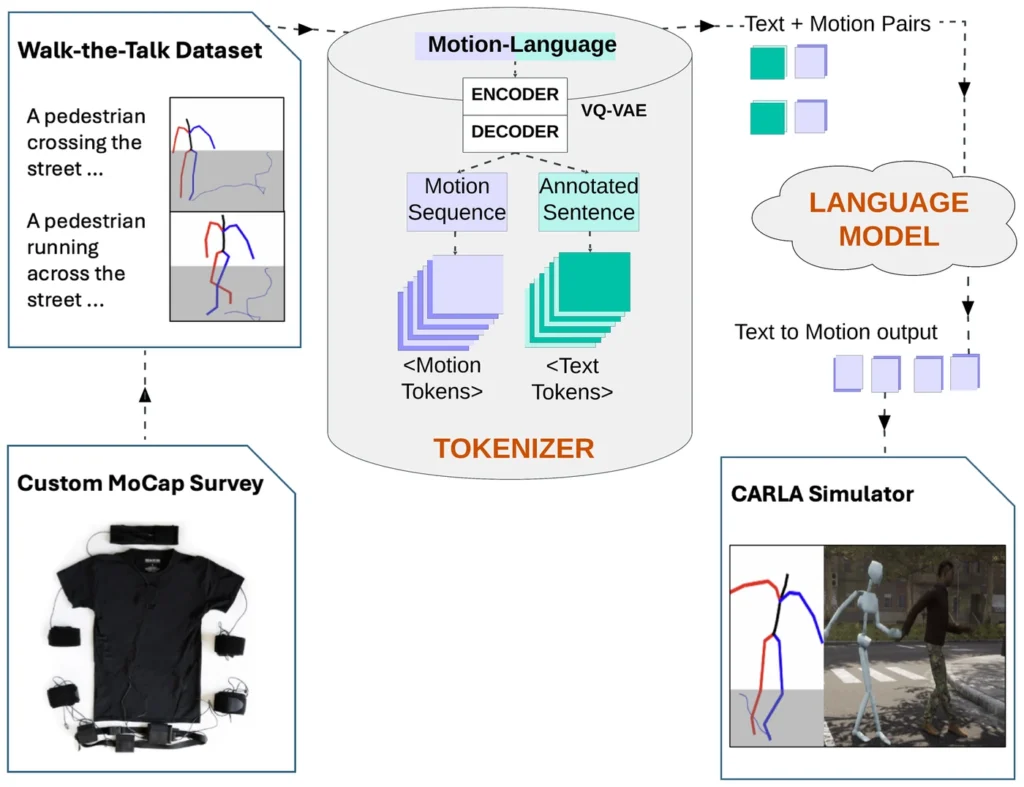
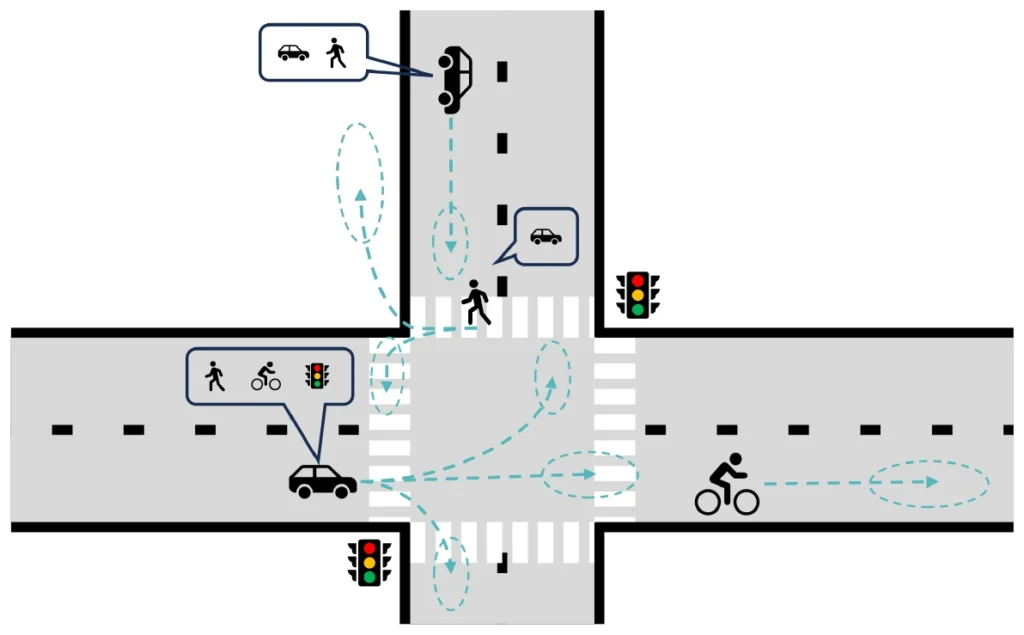
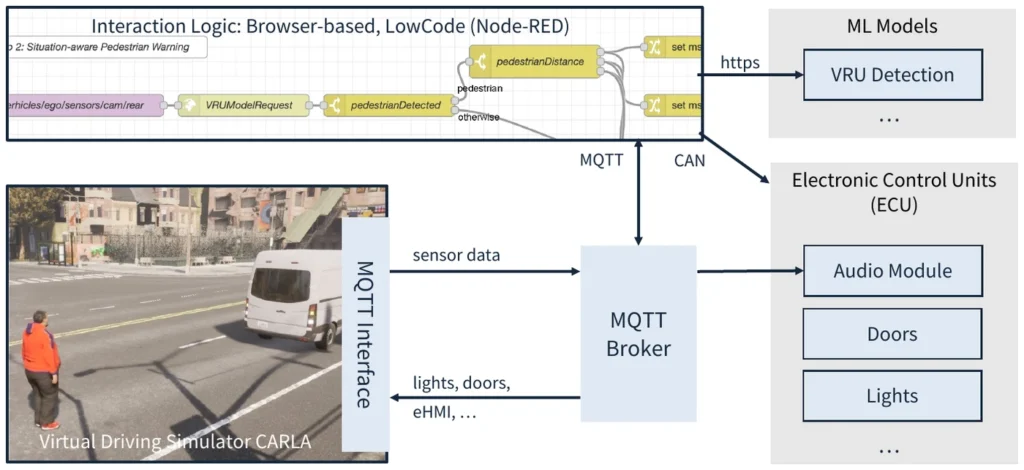
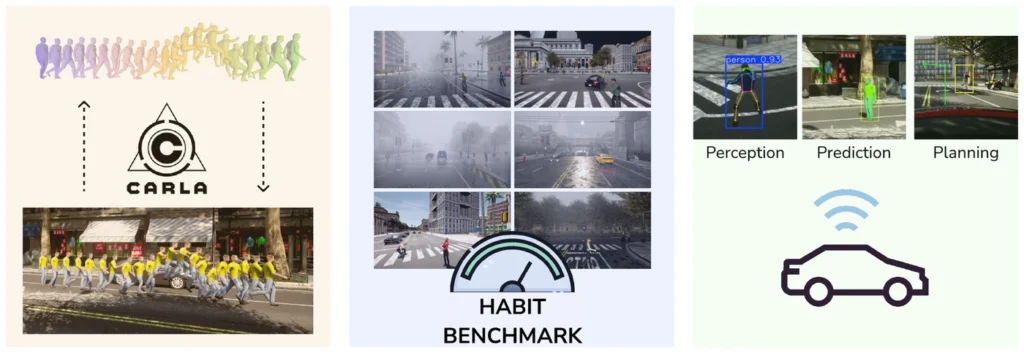
It starts with a fine-granular perception of every object — pose, shape, action and intent — and builds up to the map, the interactions, the plan and the simulation that tests it.

6themes41project pages3publicly funded projects

Projects & papers

Publicly funded projects

information page for each project
BMFTR · 2025 – 2029

ADRIVE-GPT

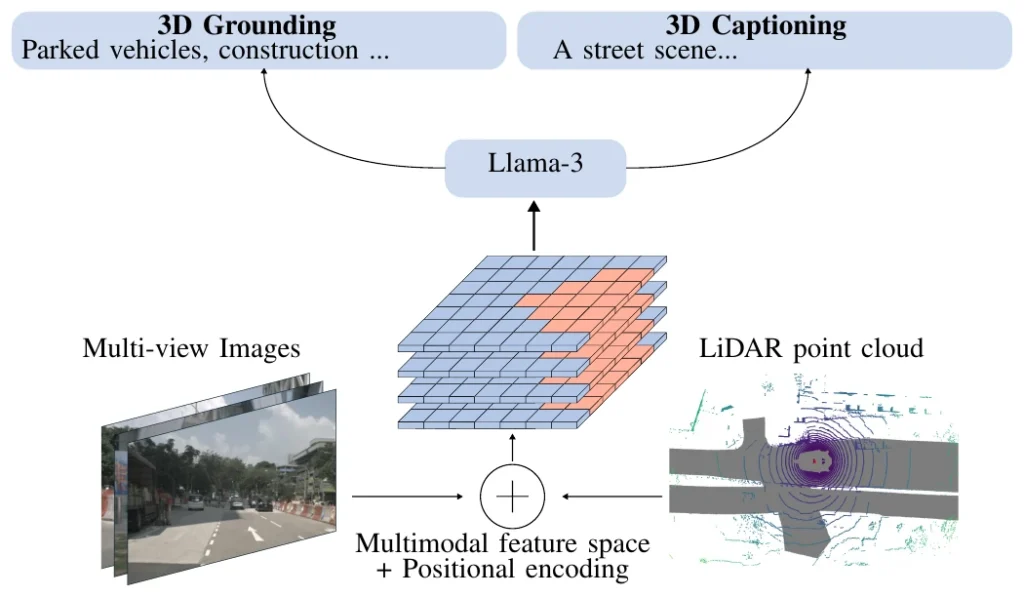
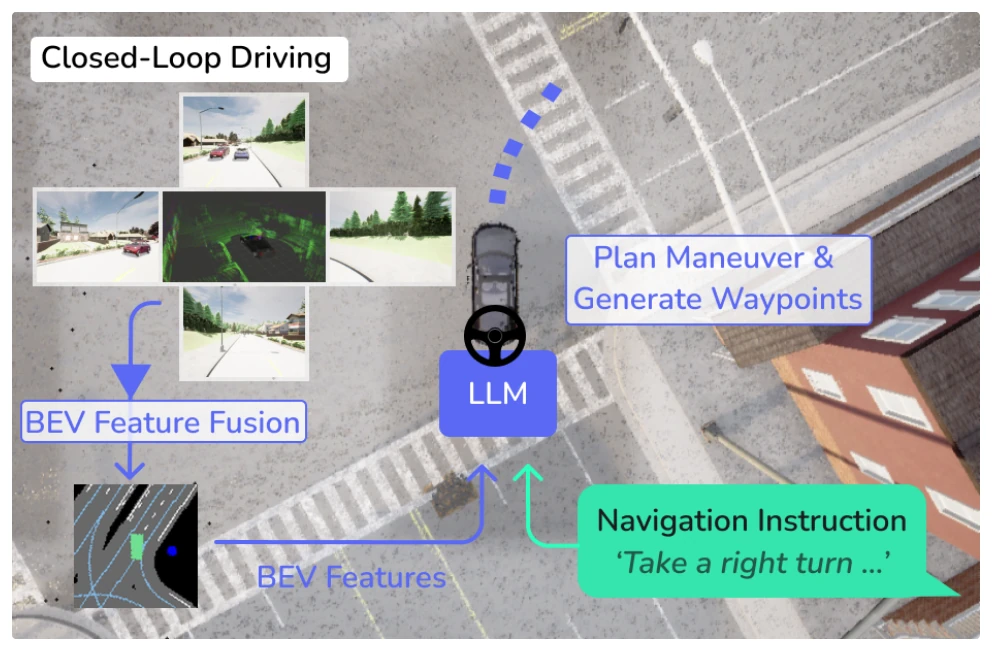
Joint project of HM and Hochschule Esslingen with Mercedes-Benz and Spleenlab on large language models for automated driving – from camera and lidar perception to language-based action plans.

BMWE · 2024 – 2026

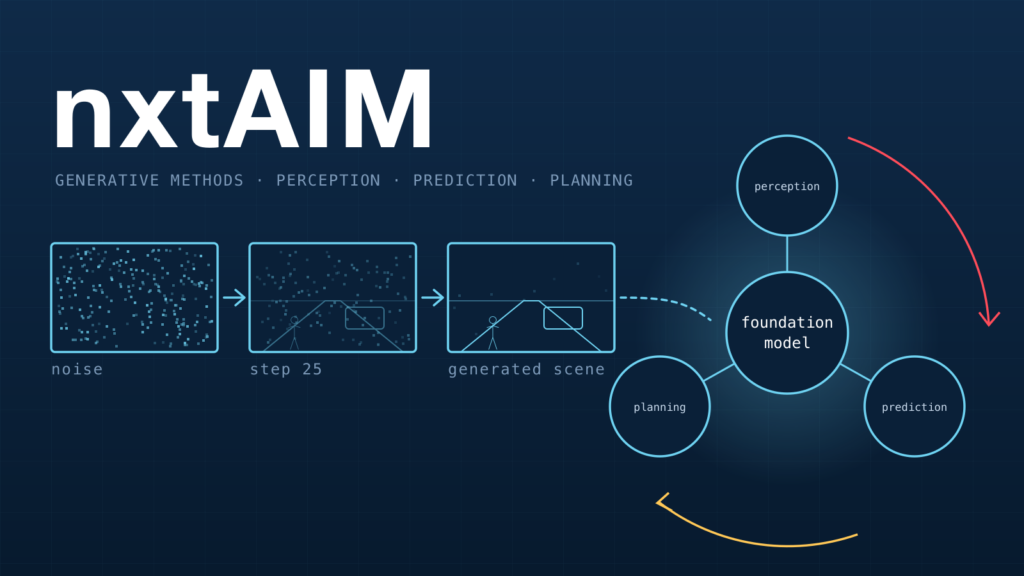
nxtAIM

Joint project using generative AI to overcome the limits of today's automated driving functions. HM's Intelligent Vehicles Lab works on generative sensor data, scene prediction and foundation models.

BMWE · 2023 – 2026

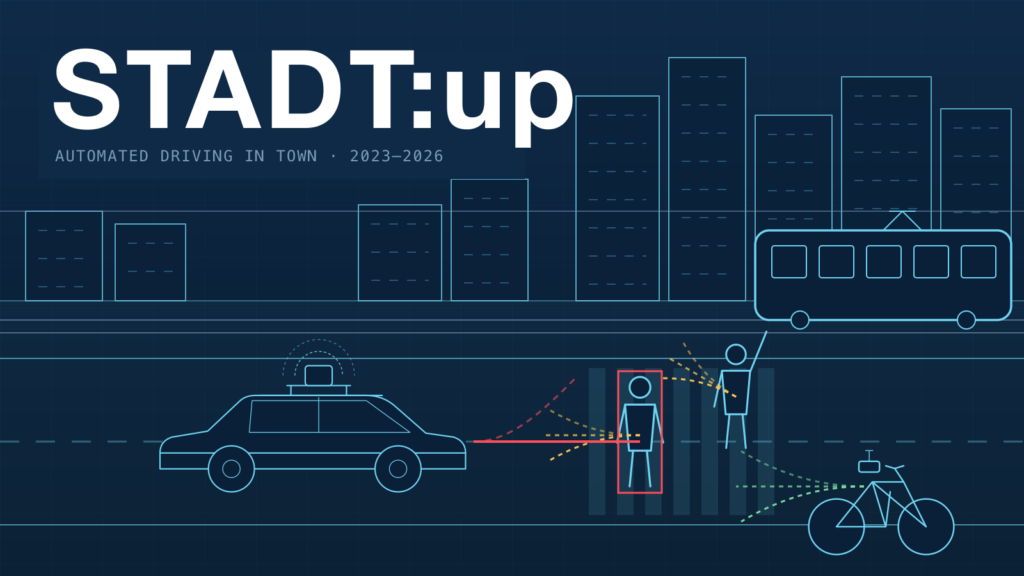
STADT:up

Joint research project on end-to-end automated driving in urban traffic (2023–2026). HM's Intelligent Vehicles Lab developed AI methods to detect pedestrians and cyclists and predict their behaviour.