Theses & Projects

Write your thesis on a research vehicle.

Every open topic says what you would build and names the person to write to.

5open topics4running4completed

Available topics

DRAWN · MAPS
Masterposted 2026-07-30

From HD map to drivable simulation town

Take a vectorised HD map of a real Munich intersection and turn it into a CARLA town that HABIT can run scenarios in, so we can evaluate on the places we actually record.

Python, CARLA, some 3D tooling. Good if you like making things fit together.
HMDRAWN · FIELDWORK
Masterposted 2026-08-28

Fusing onboard maps with satellite priors

SatMap uses satellite imagery as a prior, LIE enhances LiDAR intensity. Combine the two: use the scanner where the imagery is stale and the imagery where the scanner is blind, and measure what each contributes.

PyTorch, 3D geometry, willingness to work with nuScenes and our own recordings.

DRAWN · GENERATIVE
Masterposted 2026-08-14

End-to-end trajectory planning with generative models

Diffusion policies and language-model planners both produce trajectories, and they fail in different ways. Implement both in our closed-loop CARLA setting and find out where each breaks.

PyTorch, CARLA or a willingness to learn it, curiosity about generative models.

HMDRAWN · FIELDWORK
Bachelorposted 2026-09-05

An explainability score for end-to-end driving

End-to-end planners produce a trajectory and no reason for it. Define a measurable score for how well a model’s stated reason matches what it actually did, and evaluate it on BEVDriver.

Python, some familiarity with deep learning. An interest in evaluation design matters more than experience.

Masterposted 2026-09-02

Auto-labelling pipeline for multi-sensor recordings

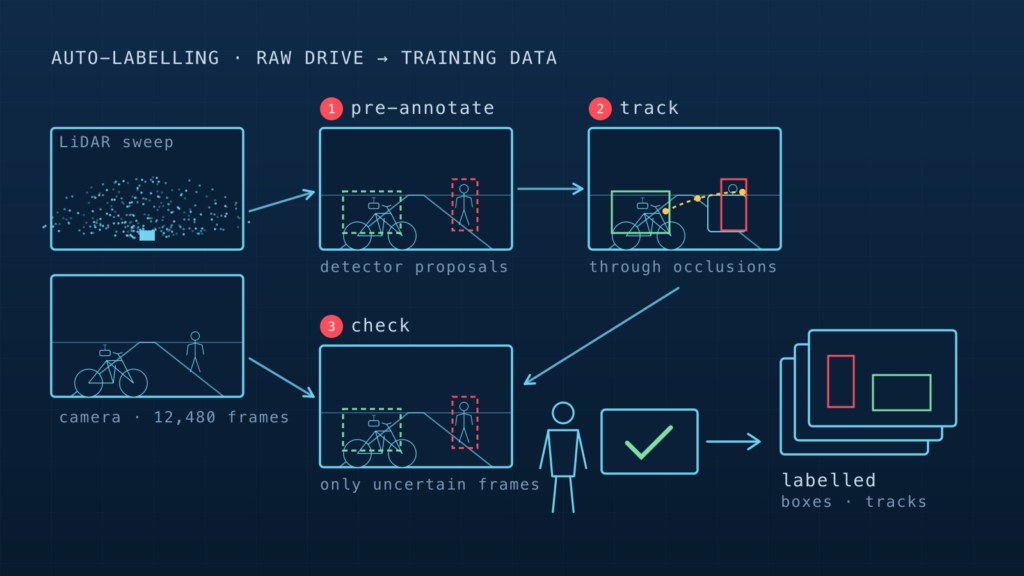
A recording day produces hours of LiDAR and camera data and almost no labels. Build the pipeline that turns a raw drive into training data: pre-annotate with existing detectors, track through occlusions, and surface only the frames a human still has to check.

Python, PyTorch, patience with real data. ROS 2 helps but can be learned here.

Running now

TopicKindSupervisorSince
Scenario generation from aerial recordingsTurning DeepUrban's aerial interactions into replayable CARLA scenarios.BAConstantin Selzer2026-06
Explainability probes for BEVDriverTesting whether BEVDriver's stated reasons correspond to the features it actually uses.BAKatharina Winter2026-08
Occlusion-aware fusion of satellite priorsDeciding per map element whether the prior or the live sensor should be trusted.MAKanak Mazumder2026-05
Cyclist intention from 3D pose sequencesBuilding on bikeActions: predicting a cyclist's next manoeuvre from a sequence of 3D poses rather than from the trajectory alone.MAMax A. Büttner2026-04

Completed

TopicKindSupervisorFinishedWhat came of it
Human action scenarios in CARLAMAMohan Ramesh2025-10Fed into HABIT, WACV 2026.
Open-vocabulary retrieval of driving motionStefan EnglmeierMAMax A. Büttner2025-03Published as ContextMotionCLIP; the author is now a PhD candidate in the lab.
Action labels for cyclist recordingsLuca Köcher, Mario Finkbeiner and Sebastian NieblerMAMax A. Büttner2025-12Became bikeActions, ICPR 2026 — all three are co-authors.
Scene captioning from multimodal BEV mapsFelix BrandstätterMAKatharina Winter2025-04Published as BEV-LLM with the student as first author.