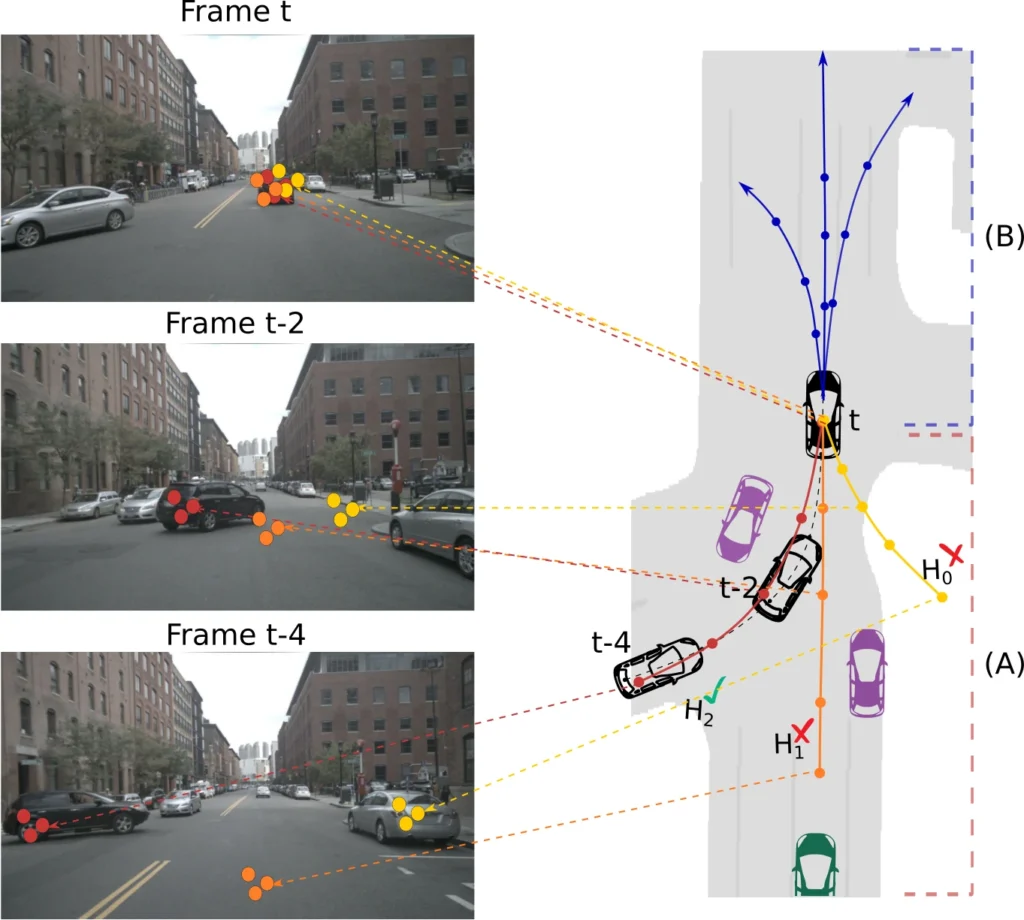
MASAR: Motion-appearance synergy refinement for joint detection and trajectory forecasting
M. A. Bencheikh Lehocine, J. Schmidt, F. Moosmann, D. Gupta, F. B. Flohr
Intelligent Vehicles Lab · Hochschule München
A vehicle or a robot has to make sense of everything around it: the road and the map, every other agent, and above all the people.
M. A. Bencheikh Lehocine, J. Schmidt, F. Moosmann, D. Gupta, F. B. Flohr
K. Mazumder, F. B. Flohr
M. A. Buettner, E. Schuetz, F. B. Flohr
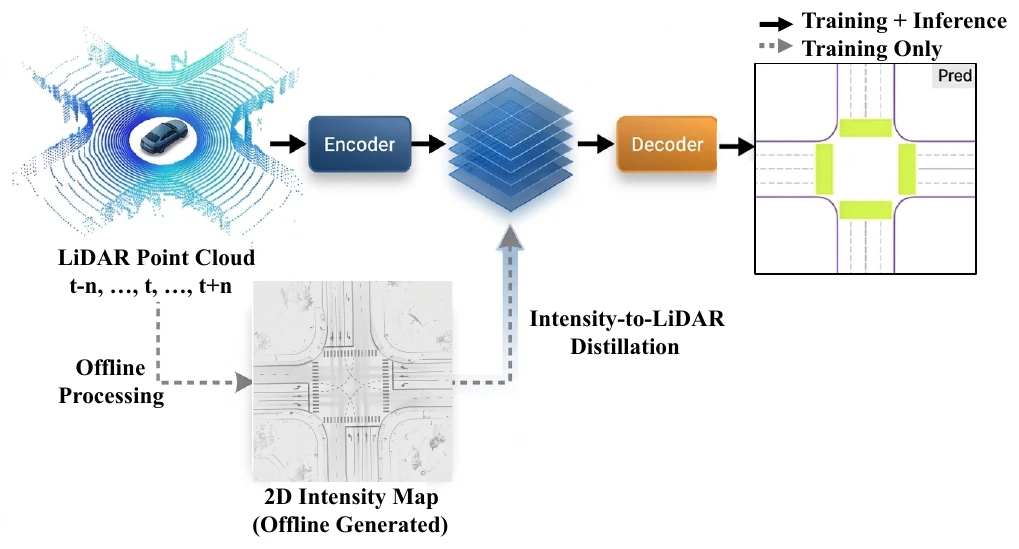
Kanak Mazumder presents LIE (ITSC 2026): LiDAR-only HD map construction with online knowledge distillation. Open to all students, no registration.
Every supervisor presents their open topics in five minutes, then you can talk to them directly. Bring your transcript if you want to apply on the spot.
Three days away from the lab to set the research agenda for the coming year.
Take a vectorised HD map of a real Munich intersection and turn it into a CARLA town that HABIT can run scenarios in, so we can evaluate on the places we actually record.
Python, CARLA, some 3D tooling. Good if you like making things fit together.
SatMap uses satellite imagery as a prior, LIE enhances LiDAR intensity. Combine the two: use the scanner where the imagery is stale and the imagery where the scanner is blind, and measure what each contributes.
PyTorch, 3D geometry, willingness to work with nuScenes and our own recordings.
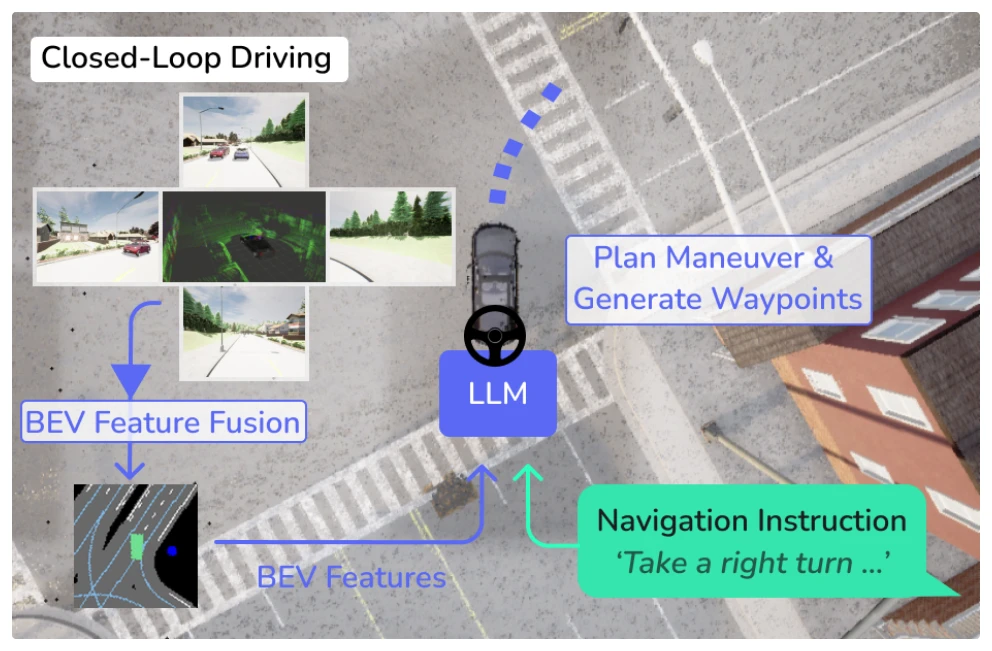
Diffusion policies and language-model planners both produce trajectories, and they fail in different ways. Implement both in our closed-loop CARLA setting and find out where each breaks.
PyTorch, CARLA or a willingness to learn it, curiosity about generative models.
Preliminary postings. Every position below still has to be confirmed by the Intelligent Vehicles Lab and by HR; details may change.
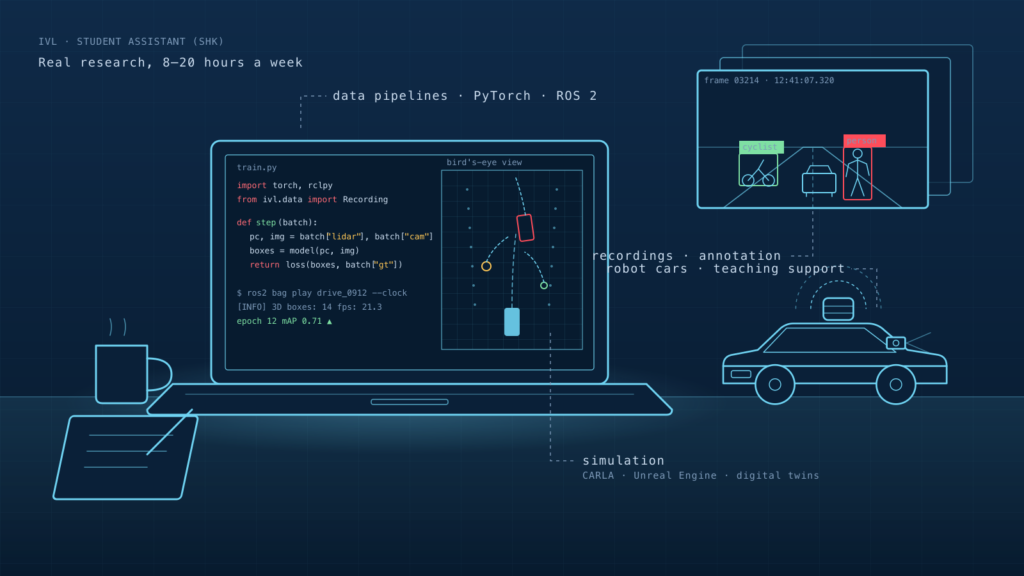
Work alongside the PhD candidates on real research — recordings with the research vehicle, data pipelines, simulation or the vehicle software — for 8 to 20 hours a week next to your studies.
Build driving models that do not just react to the scenes they were trained on, but generalise, reason and explain — generative world models, vision-language-action models and the step from narrow autonomy towards general intelligence in automated driving.
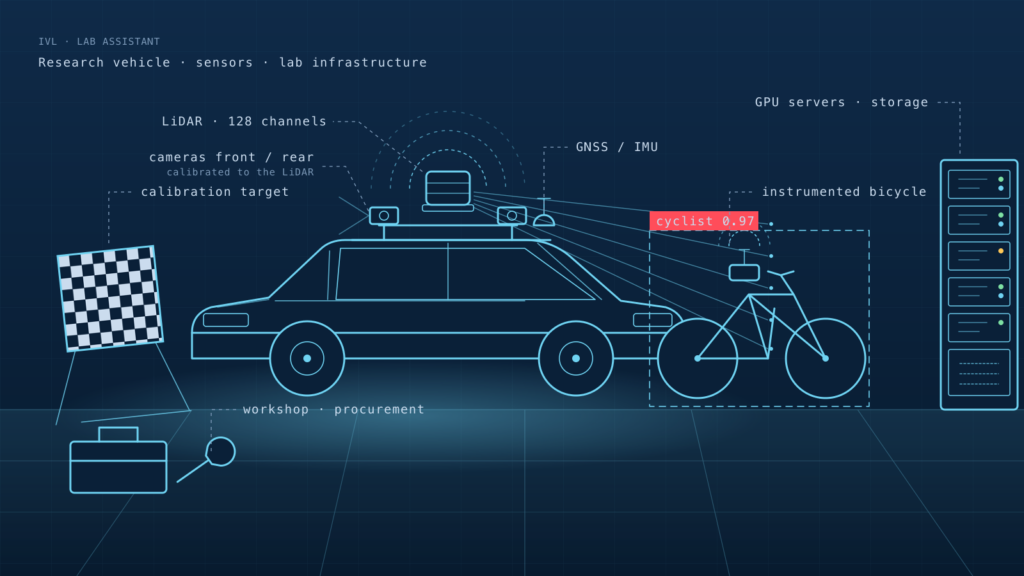
Keep the lab running: the research vehicle and its sensors, the instrumented bicycle, the GPU servers and the recording campaigns that every result of the lab depends on.