STADT:up
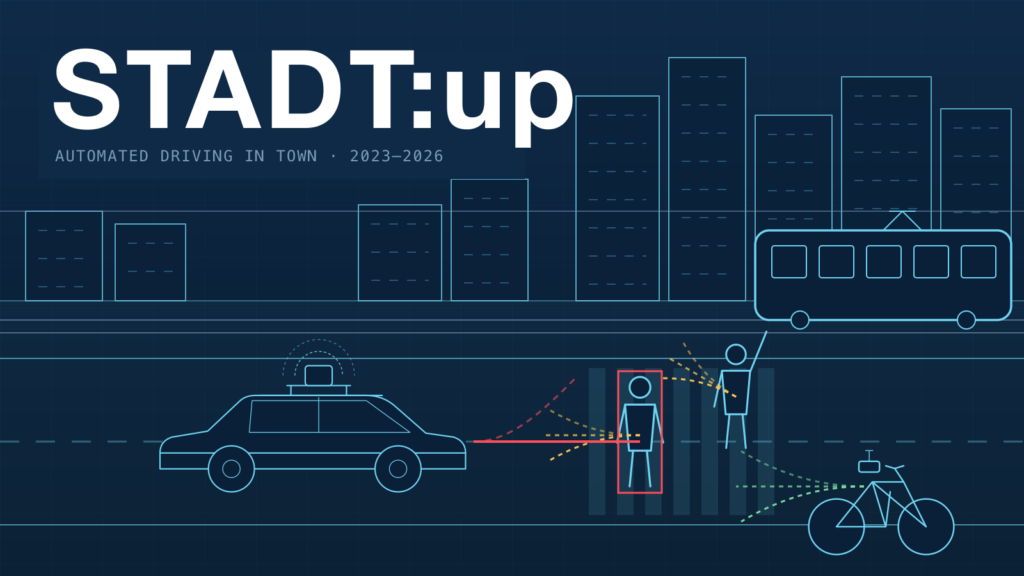
Joint research project on end-to-end automated driving in urban traffic (2023–2026). HM’s Intelligent Vehicles Lab developed AI methods to detect pedestrians and cyclists and predict their behaviour.
About the project
STADT:up (Solutions and Technologies for Automated Driving in Town) was a collaborative research project in which vehicle manufacturers, suppliers, technology companies and research institutions developed concepts and pilot applications for end-to-end automated driving in urban traffic. Funded by the German Federal Ministry for Economic Affairs (BMWK, now BMWE) in the programme “New Vehicle and System Technologies”, it ran from January 2023 to June 2026 with a total budget of around EUR 62 million and was coordinated by Robert Bosch GmbH. The project addressed the complete functional chain of an automated vehicle – perception, fusion, localisation, environment model, prediction, interaction and cooperation through to behaviour and manoeuvre planning – aiming at robust, adaptive trajectory planning based on multimodal prediction of all road users. STADT:up also studied interaction and communication between users, automated vehicles and other road users, and developed perspectives for future intermodal mobility together with cities, users, research institutions and industry, including the question of how mixed traffic of pedestrians, cyclists, private and shared vehicles and public transport will evolve. The project closed with a final event at the Aldenhoven Testing Center in June 2026, where the partners demonstrated their prototypes in realistic urban scenarios.
Our contribution
HM’s sub-project on inner-city automated driving functions with a focus on data-driven sensor data fusion, object analysis, behaviour prediction and planning was carried out by the Intelligent Vehicles Lab under Prof. Dr. Fabian Flohr. The lab focused on accurate detection and behaviour prediction of vulnerable road users such as pedestrians and cyclists and on behaviour planning derived from it, using learning-based, scalable, data-driven methods. At the final demonstration HM presented three developments: the research vehicle AVA, which anticipates where pedestrians will move next; a VR-based simulation environment in which test persons control virtual pedestrians in CARLA via motion capture and speech; and the FUSE-Bike, a sensor-equipped e-bike for data collection and cooperative perception.