PedCut: an iterative framework for pedestrian segmentation combining shape models and multiple data cues
Abstract
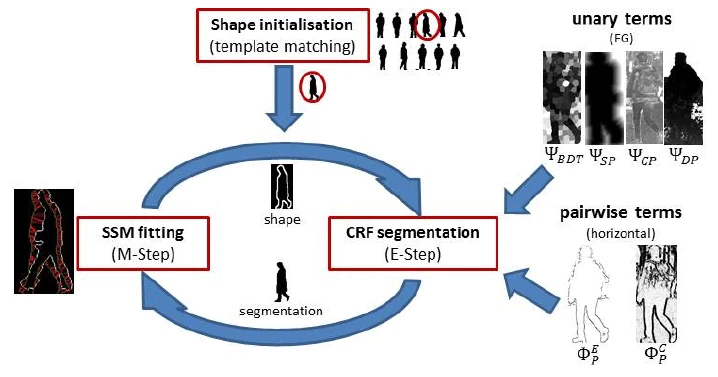
This paper presents an iterative, EM-like framework for accurate pedestrian segmentation, combining generative shape models and multiple data cues. In the E-step, shape priors are introduced in the unary terms of a Conditional Random Field (CRF) formulation, joining other data terms derived from color, texture and disparity cues. In the M-step, the resulting segmentation is used to adapt an Active Shape Model (ASM), after which the EM process alternates. Experiments on the public Penn-Fudan pedestrian dataset suggest that our method outperforms the state-of-the-art. We further provide results on a new Daimler pedestrian dataset, captured from on-board a vehicle, which includes disparity data. This dataset is made public to facilitate benchmarking.
Citation
@inproceedings{Flohr2013PedCut,
title = {PedCut: an iterative framework for pedestrian segmentation combining shape models and multiple data cues},
author = {Fabian B Flohr and Dariu M Gavrila},
year  = {2013},
date = {2013-01-01},
booktitle = {British Machine Vision Conference (BMVC)},
publisher = {BMVA},
keywords = {},
pubstate = {published},
tppubtype = {inproceedings}
}