Building a computer vision research vehicle with ROS
Abstract
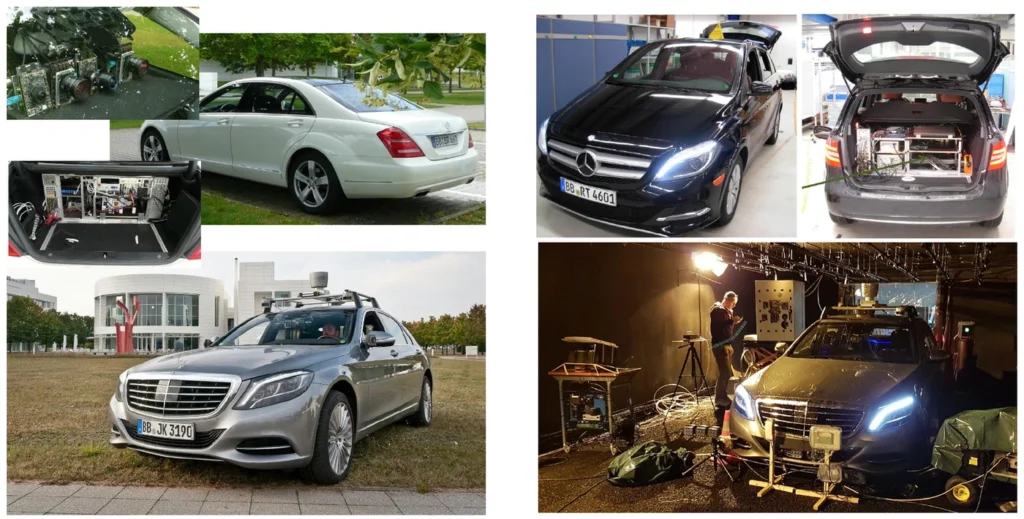
Daimler (Mercedes-Benz) has a long history on research and development on ADAS systems and autonomous driving. Today’s increasing complex requirements on sensors, algorithms and fusion put high demands on the underlying software framework. In this talk, the group Pattern Recognition and Cameras of Daimler Research and Development showcase their latest research vehicle. Additionally, a detailed look on an implemented multi-sensor synchronization system is given. Findings and lessons learned as well as tool modifications and added functionality will be discussed as well. The audience will get insights on data handling in the context of high data throughput.
Citation
@article{Fregin2017Buildingacom,
title = {Building a computer vision research vehicle with ROS},
author = {Andreas Fregin and Markus Roth and Markus Braun and Sebastian Krebs and Fabian B Flohr},
year  = {2017},
date = {2017-01-01},
journal = {ROSCon 2017},
volume = {21},
keywords = {},
pubstate = {published},
tppubtype = {article}
}